

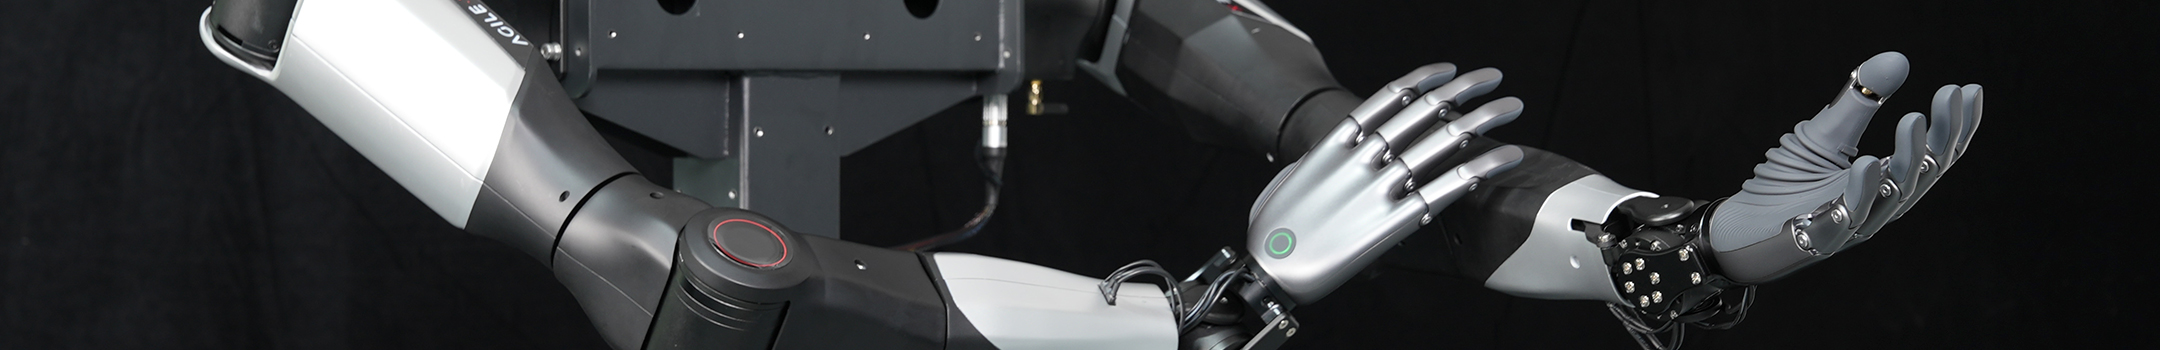
Robotics
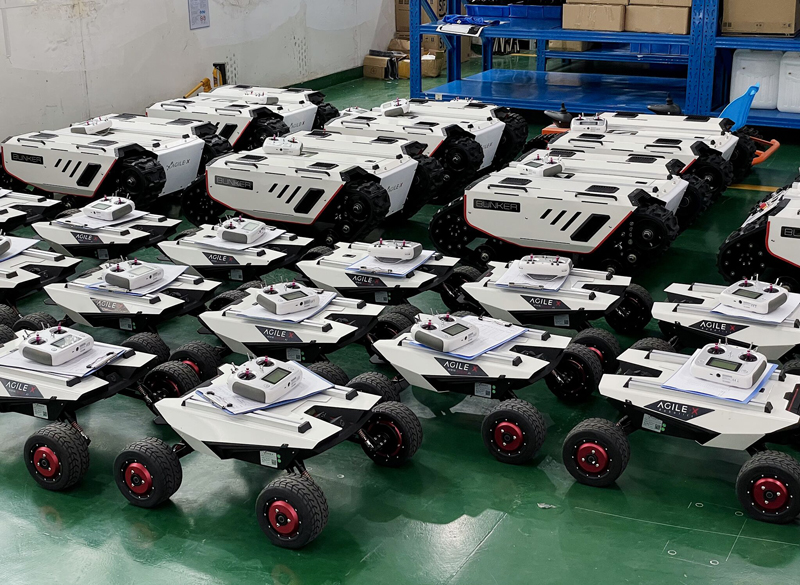
FAST Assembler places a strong emphasis on robotic technology, making itself autonomous in developing applications that make use of robots.
The added value of these technologies is the expertise and mastery in developing dedicated software, allowing the integration potential of these robots or automatic systems to be fully exploited.
The dynamism of technological development has allowed Fast Assembler to establish itself quickly in the field of industrial robotics. Benefiting from the latest technologies, the company has optimized its entire department, achieving excellent results in terms of both quality and quantity. The integration of artificial intelligence and vision systems has delivered excellent results in the integrated products: precision at every stage of processing is nearly perfect, guaranteeing the end customer a superior and consistent quality standard.
FAST Assembler
uses robots:
Collaborative
The so-called cobots or robotic arms enable integration for applications that require human-machine collaboration, for example bringing manual assembly to a technologically advanced level. This technology is used in areas where integration must be flexible and ready to undergo sudden, drastic changes over time, thus offering the possibility of quick redeployment. Fields of application range from assembly lines, packaging, food&beverage, up to the creation of test/inspection cells for products or machinery. The cobot is equipped with tools chosen ad hoc for the specific application, including end-effectors and 2D and 3D vision systems.
The work area (reach) is carefully studied, as is the footprint of the robotic arm, ensuring that every movement is optimized for maximum speed without compromising safety or mechanics.
Delta Robot
Where maximum execution speed is required (pick&place, machine tending, sorting, etc.), FAST Assembler can build automated lines made up of a single Delta Robot or a fleet of Delta Robots, also building, on specific request, the handling tools mounted on the robot’s wrist. FAST Assembler integrates this technology mechanically and at software level into any industrial process or line.
Mobile Robotics (UGV, AGV, AMR)
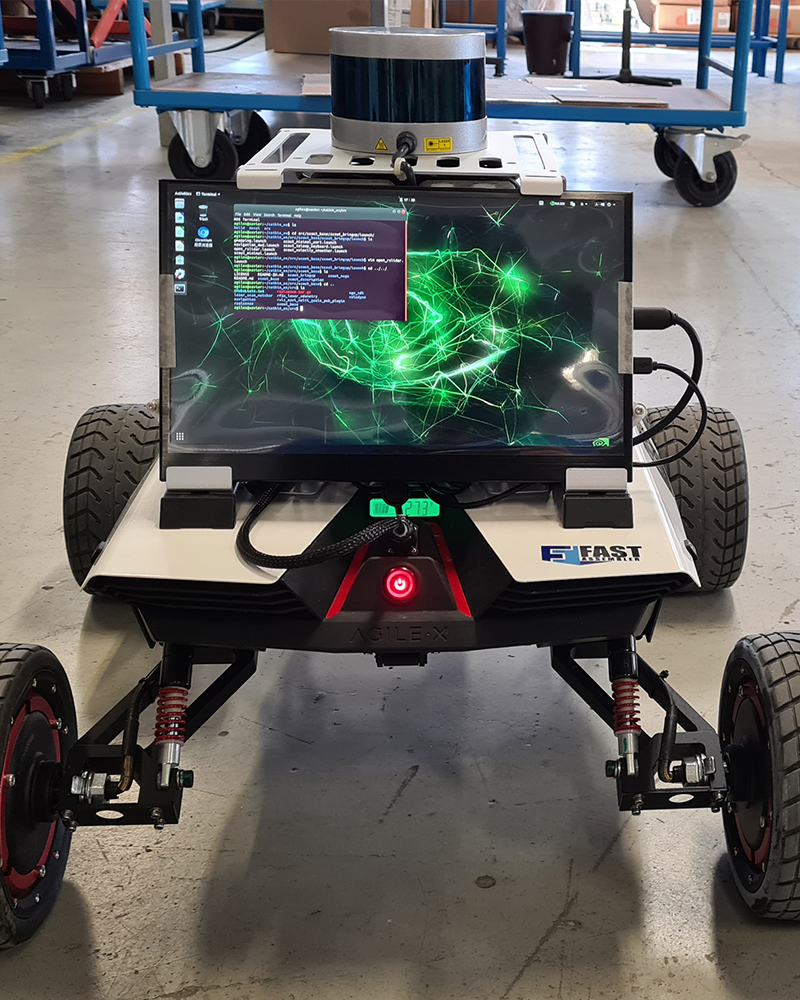
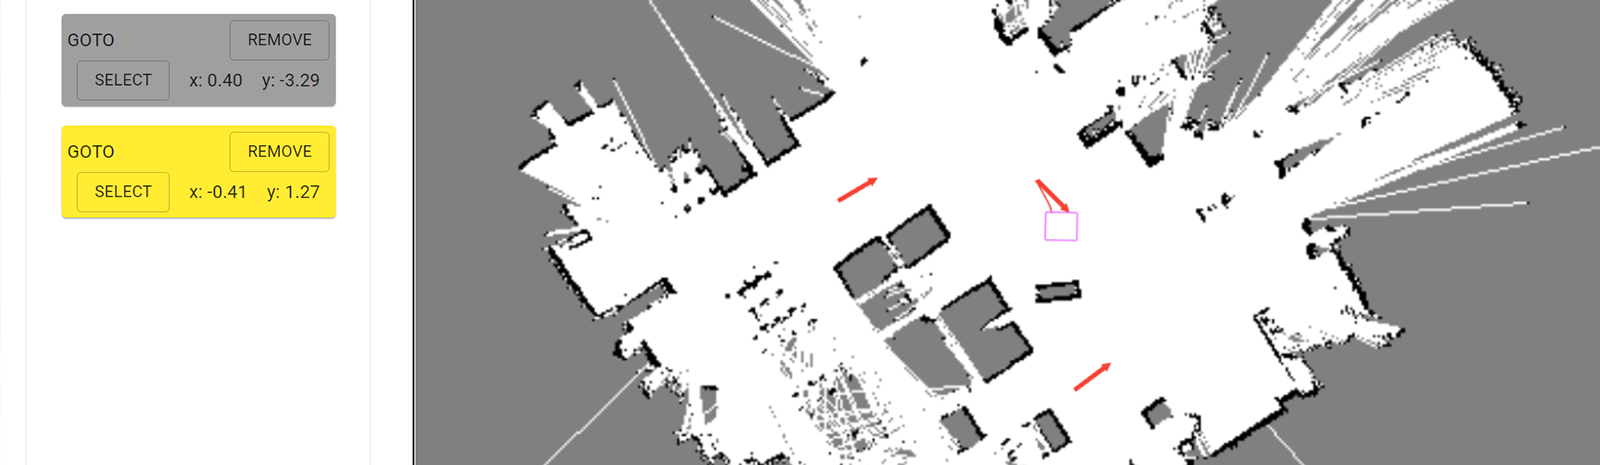
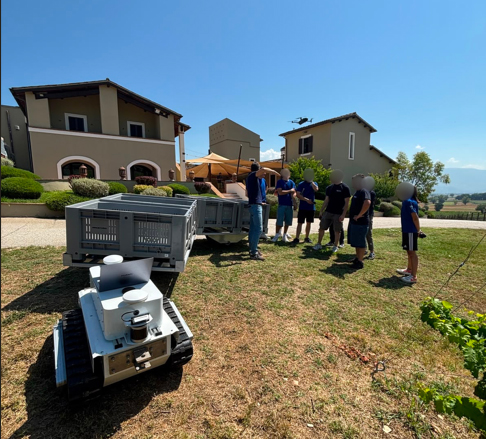
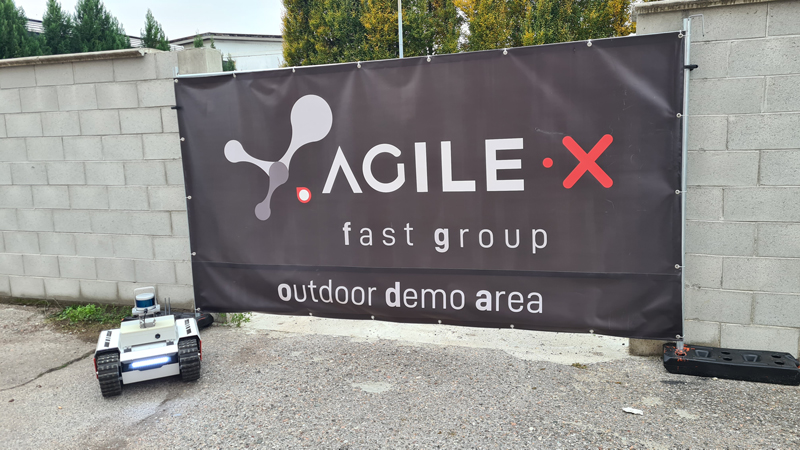
FAST Assembler’s innovation also extends to autonomous mobile robots. These navigate dynamic environments without the need for fixed infrastructure, using advanced sensing and simultaneous localization and mapping (SLAM) algorithms. Although intralogistics remains a fundamental pillar, the company designs robotic solutions capable of going beyond simple transport, from agriculture to R&D, from pick-and-place to inspection and monitoring in outdoor and/or special environments.
Towards
Industry 5.0
FAST Assembler is establishing itself on the market as a strategic partner and distributor of outstanding robotic technologies, offering a broad portfolio that also includes products such as robotic hands, quadruped (canine) systems and humanoid robots. As a distributor, the company guarantees priority access to innovations, genuine spare parts and specialized technical support, integrating different brands into coherent solutions in line with customers’ needs.
Thanks to its own demo room, FAST Assembler also allows these technologies to be tested and compared in practice, ensuring the selection of the most efficient and technologically advanced configuration for each specific project. A concrete approach that turns the paradigms of Industry 4.0 into real solutions, optimizing the productivity and flexibility of industrial processes.
Our
official partners
Case study
University of Udine
SLAM-Based Mapping
Scalera, L., et al. (2026). Forest Surveying with Robotics and AI: SLAM-Based Mapping, Terrain-Aware Navigation, and Tree Parameter Estimation. Machines, 14(1), 99.
Mapping
Scalera, L., et al. (2025). Mobile Robotics for Forest Monitoring and Mapping Within the AI4FOREST Project. In International Conference Mechanical Engineering Solutions: Design, Simulation, Testing, Manufacturing (pp. 279-288). Cham: Springer Nature Switzerland.
3D Mapping
Tiozzo Fasiolo, D., Scalera, L., Maset, E., Gasparetto, A. (2025). The FriûlBot dataset: Experimental validation of an autonomous ground robot for vineyard 3D mapping. Robotics and Autonomous Systems, 105283.
Navigation
Tiozzo Fasiolo, D., Scalera, L., Maset, E., Gasparetto, A. (2025). Field Evaluation of an Autonomous Mobile Robot for Navigation and Mapping in Forest. Robotics, 14(7), 89.
Autonomous
Tiozzo Fasiolo, D., et al. (2025). A Navigation Approach for Autonomous Mobile Robots in Sustainable Agriculture. In International Workshop IFToMM for Sustainable Development Goals (pp. 399-408). Cham: Springer Nature Switzerland.
Navigation
Tiozzo Fasiolo, D., Pichierri, A., Sivilotti, P., Scalera, L. (2023). An analysis of the effects of water regime on grapevine canopy status using a UAV and a mobile robot. Smart Agricultural Technology, 6, 100344.
Mapping
Tiozzo Fasiolo, D., Scalera, L., Maset, E., Gasparetto, A. (2024). Robotic Mapping and Detection of Dynamic Objects in Outdoor Environments. In European Conference on Mechanism Science (pp. 245-252). Cham: Springer Nature Switzerland.
Got a project in mind? Contact us!